Collective / Fleet Intelligence
Many robots as one system—assignment, deconfliction, shared maps, and network-aware coordination.
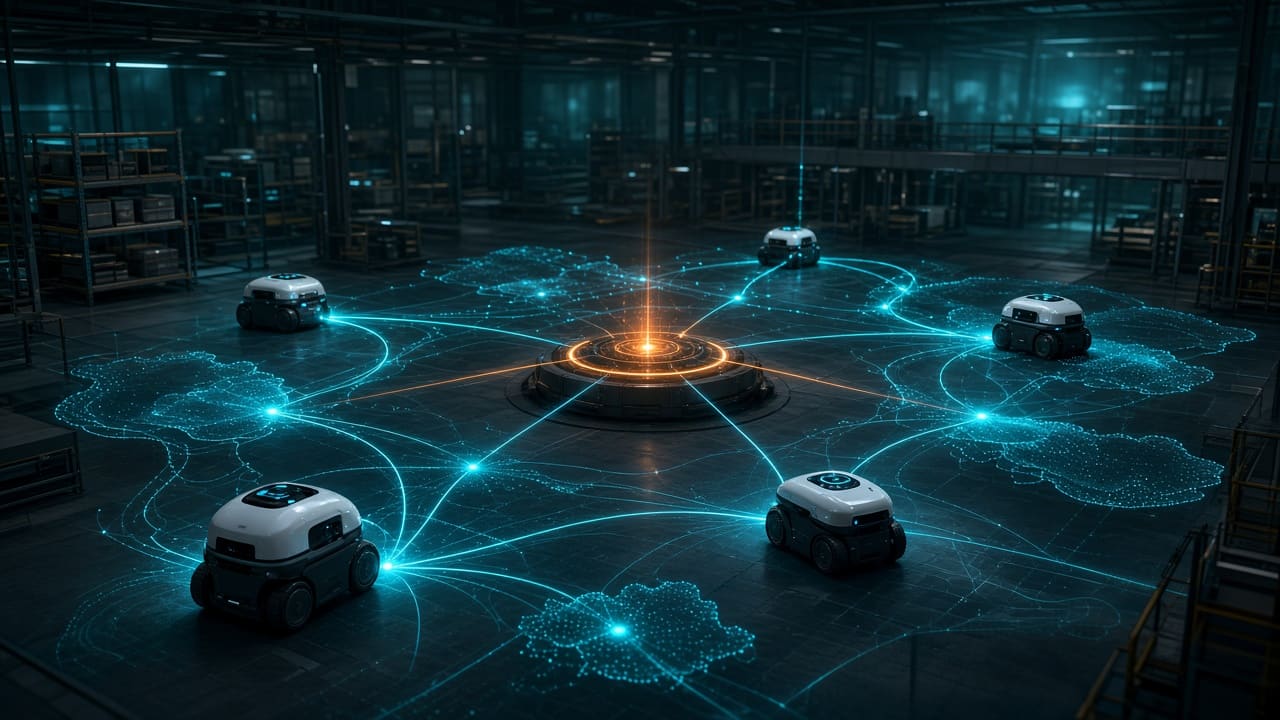
Coordination across robots—not a single robot’s mission brain.
A single capable robot still hits limits of reach, time, and coverage. Fleets matter when work spans floors, shifts, and mixed robot types—especially when people and fixed infrastructure are part of the same system.
This program studies shared maps, task allocation, communication, and coordination patterns that keep multi-robot work coherent without becoming brittle.
It extends Spatial AI and Autonomous Physical Work into operations where many agents must agree on space, priority, and progress.
Fleet intelligence is coordination under partial information: assignment, conflict, shared maps, and bandwidth. We study allocation algorithms and DDS-era middleware in multi-agent simulation and network models, then continue live multi-robot radio and traffic tests with partners.
Scope: This program owns multi-agent coordination: allocation, traffic, shared map consistency, and partition behaviour. A single robot’s mission executive stays in Autonomous Physical Work; per-robot maps and scenes in Spatial AI.
Durable layers of the program.
Allocation, communication, and agreement layers for fleets—without replacing single-robot autonomy or spatial perception research.
- Shared maps
- Task allocation
- Robot-to-robot messaging
- Fleet scheduling
- Conflict resolution
- Human–fleet interfaces
- Infrastructure bridges
- Multi-robot verification
- Heterogeneous robot teams
- Operations dashboards
Allocate, communicate, agree—then move as a system.
Collective intelligence research covers task allocation, deconfliction, and shared world models. Happy-path auctions are easy in slides; we stress message loss, map disagreement, and aisle contention in simulation first, then with partner fleets when radio reality matters.
We treat the fleet as a distributed system: consensus where needed, local autonomy where possible, and explicit policies for partition.
Algorithms we study and implement
- Market-based / auction allocation (CBBA-style themes) for task assignment
- Conflict-based search and traffic deconfliction for shared spaces
- Map merging and multi-robot SLAM consistency checks
- Consensus and gossip patterns for shared state with bounded bandwidth
- Formation and coverage controllers when geometry matters
- Partition detectors with degraded solo policies when the network splits
Things we measure
- Assignment optimality gap vs. centralised oracle on small fleets
- Conflict rate (near-miss / deadlock) per robot-hour
- Shared-map divergence after concurrent exploration
- Bandwidth and latency budgets under peak tasking
- Recovery time after network partition heals
Fleets convince with sim conflict logs—and partner partition drills when scheduled.
A coordinated demo in simulation is necessary. Evidence is the messy hour—contention, radio loss, map disagreement—reproduced in multi-agent sims and, when available, on partner fleets that still make progress.
- Allocation traces comparing auction vs. naive greedy assignment
- Simulated and partner Wi-Fi impairment tests with QoS notes
- Map merge conflicts catalogued in multi-agent runs
- Operator playbooks for partition and rejoin, reviewed with fleet partners
- Portal metrics that match on-robot truth within declared latency
An open field, not a closed stack.
Fleet vendors and warehouse systems already solve pieces of this. We focus on open, heterogeneous teams that can include RoboWorks platforms and partner robots.
Adjacent work
- Warehouse fleet platforms
- AMR fleet managers
- Multi-robot research frameworks
- Orchestration middleware vendors
Partners and complements
- ROS 2 multi-robot tooling
- NVIDIA Isaac
- Spatial AI
- Autonomous Physical Work
- AgentFlow
- RoboWorks
- Facility infrastructure partners
A path that compounds over time.
From shared maps to reliable allocation—and eventually to mixed human–robot operations that stay understandable.
- Shared spatial state across robot types
- Task allocation with clear priorities and locks
- Resilient communication under partial failure
- Human oversight for fleet-level decisions
- Productised fleet patterns for partner deployments